Reinforcement Learning · Computer Vision
I want to build systems that can see, understand, and act in the physical world. My research sits at
the intersection of perception and decision-making, with a broad interest in spatial
intelligence —
how will machines understand, reason about, and interact with physical space.
Currently I am exploring how
Vision Language Models can be grounded
in physical action, enabling machines to semantically understand their environment and
respond to natural language with physical gestures.
Publications
WiP: DeerSense: Oh Deer, We Know What You Do! Deterrence-Aware Deer Behavior Recognition
ACM MobiCom 2026
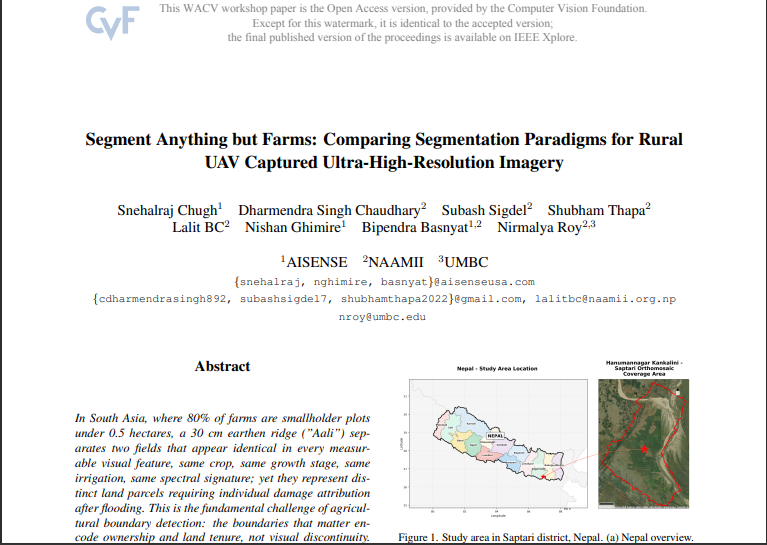
Segment Anything but Farms: Comparing Segmentation Paradigms for Rural UAV Captured Ultra-High-Resolution Imagery
WACV 2026 Workshop · GeoCV
Education
Master of Science, Research in Computer and Systems Engineering
Technische Universität Ilmenau
Bachelor of Information Technology, Computer Science
Lincoln University College
+2, Computer Science
St. Lawrence College
Experience
NAAMII
AI Engineer Intern
Telemus AI
Research & Development Intern
Robotics Association of Nepal
Projects
Personal
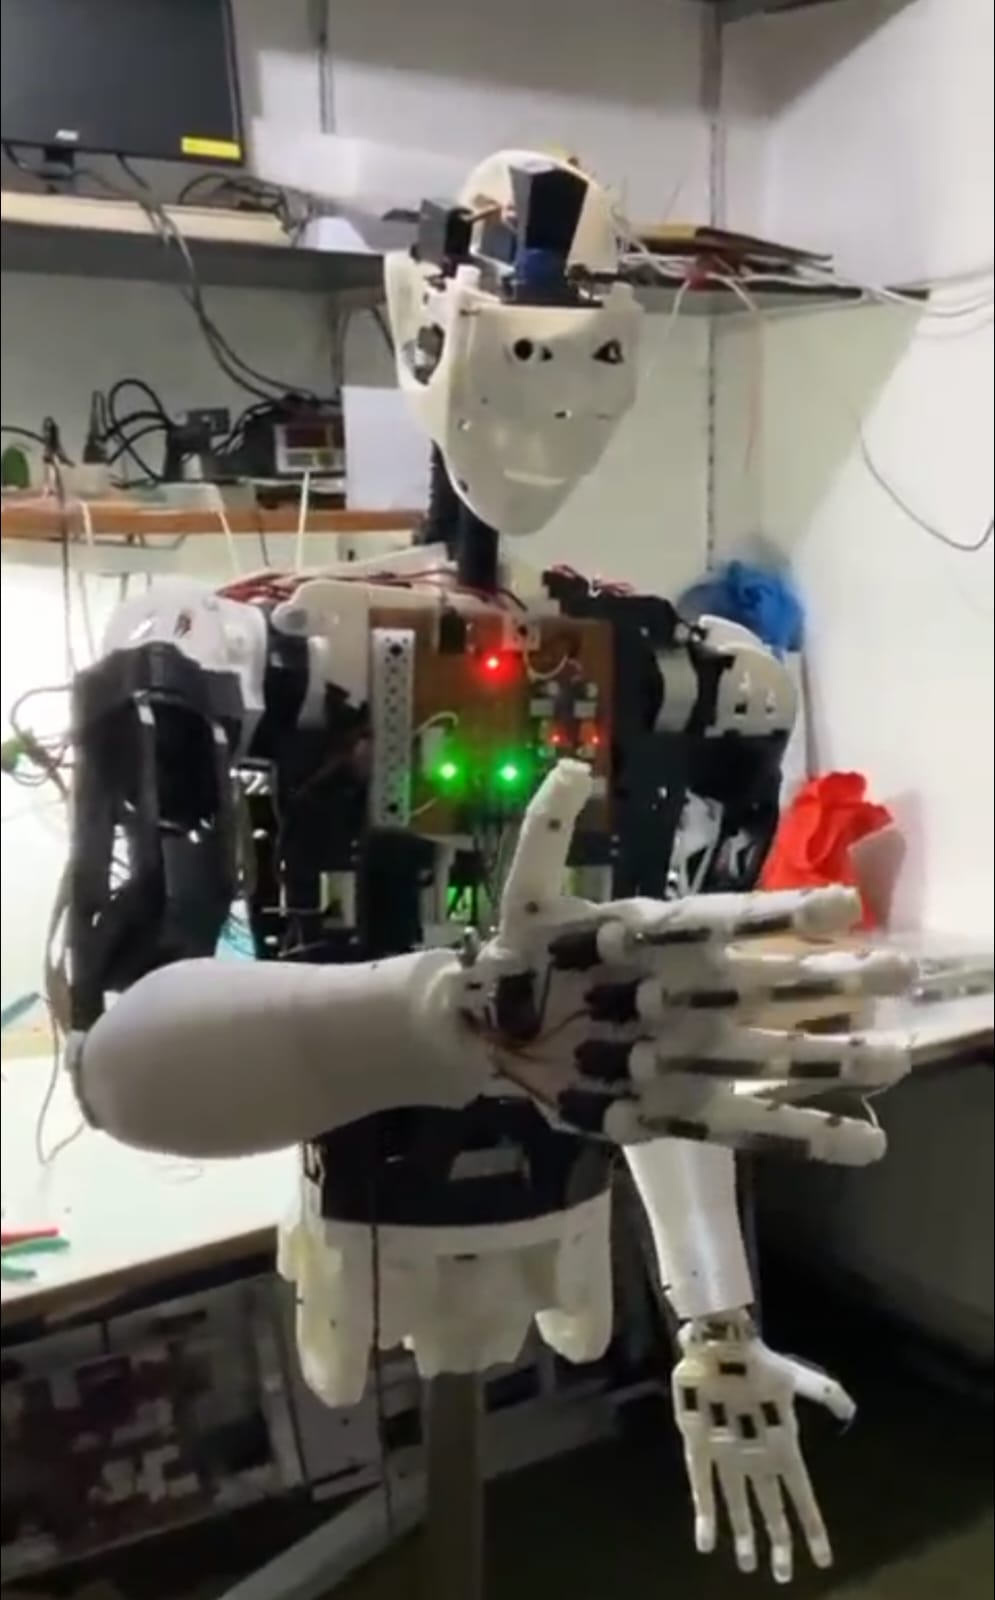
InMoov — Open-Source Humanoid Robot
🔬 OngoingBuilding and programming the InMoov humanoid robot as a research platform. Currently the robot accepts natural language voice commands and executes a set of physical actions. The ongoing research direction extends this further — integrating Vision Language Models so the robot can semantically understand its visual environment and physically point toward named objects on demand, e.g., "Where is the door?" — a step toward grounded spatial intelligence in embodied systems.
Subash Sigdel, Ram Tamang
Mentored by Muni Bahadur Shakya — Nepal's first computer scientist & pioneer
Python · ROS · OpenCV · Arduino · 3D Printing · Sensors · LLMs · VLMs
Rover — Person-Following Robot
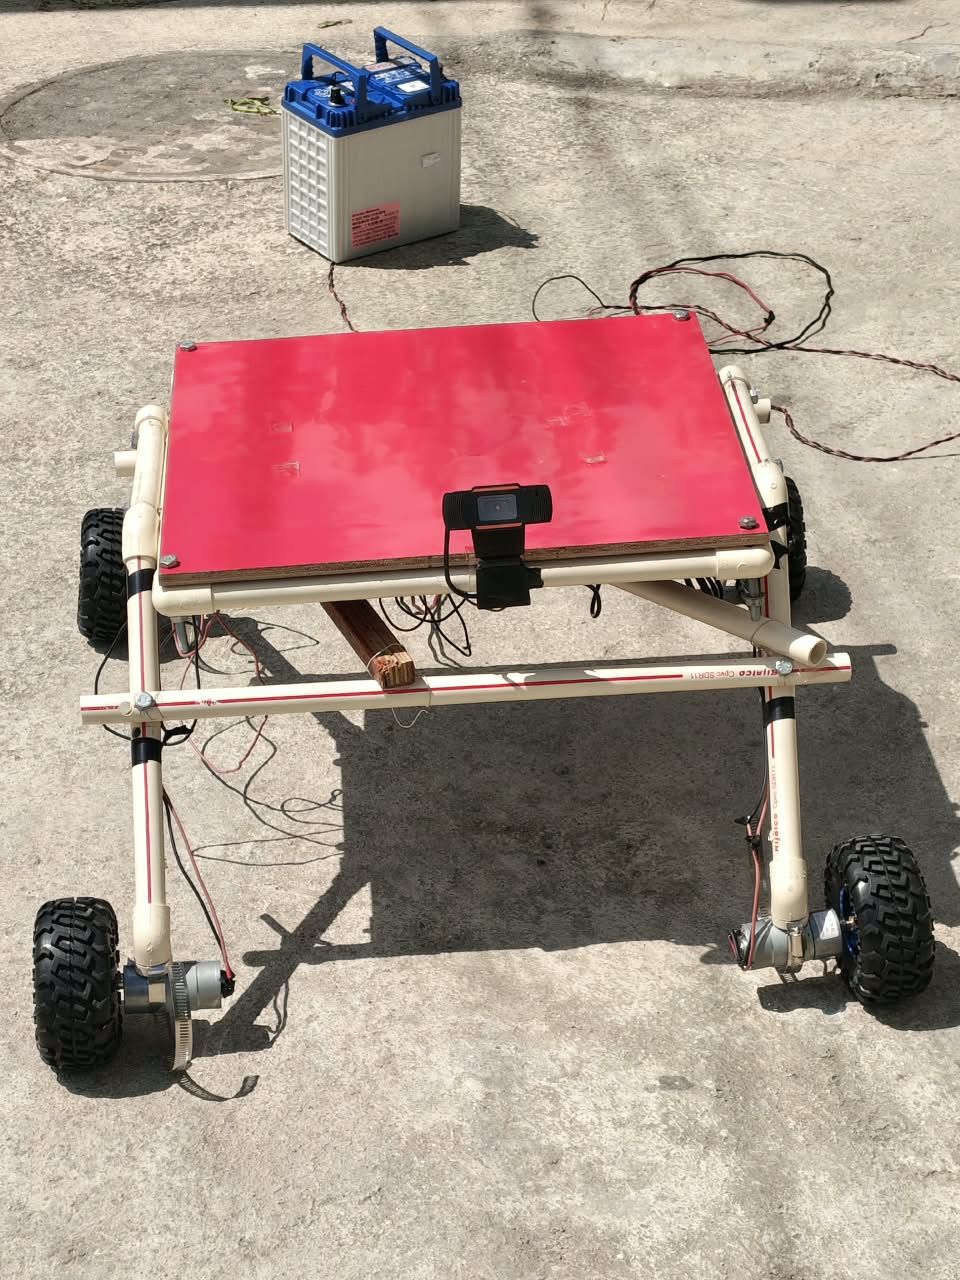
Personal ProjectA skid-steer rover that finds a person and drives after them, fully offline. A Raspberry Pi 3 runs YOLO11n on a USB webcam feed, estimates distance from the bounding-box width with a calibrated pinhole constant, and turns it into throttle and steering; an ESP32 converts those commands into motor PWM behind a 500 ms watchdog.
Python · Raspberry Pi · ESP32 · YOLO11n · ONNX · OpenCV
Traffic Prediction & Signal Control
University ProjectSmart traffic management system using real-time data and AI to predict congestion and dynamically optimize signal timings — reducing wait times and emissions.
Python · OpenCV · Flask · TensorFlow
Group
PadhaiSathi — For Visually Impaired Students
🏆 Hackathon WinnerAI-powered assistive webapp helping visually impaired students read and navigate content through audio feedback using OCR and text-to-speech.
Subash Sigdel, Zidan Rai, Arik Rai, Nima Tamang, Jiten Rai
Python · OCR · gTTS
Park Me
🏆 Hackathon WinnerSmart parking system that helps users locate the nearest available parking spot in real time via a webapp interface.
Subash Sigdel, Ram Tamang, Nischal Tamang, Sadhana Sapkota
Django · HTML · CSS
Advance Agro
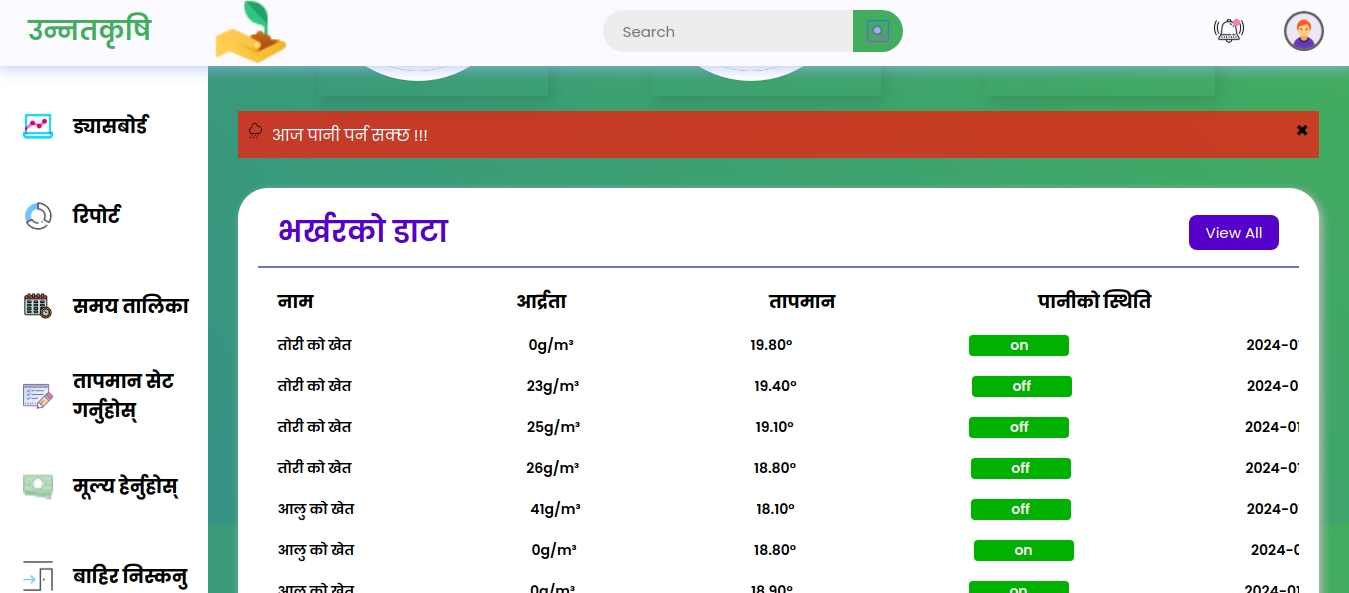
HackathonSmart agriculture assistant using soil sensors and weather APIs to recommend real-time irrigation and fertilizer plans for farmers.
Subash Sigdel, Ram Tamang, Abhay Mandal
Arduino · Sensors · Flask · ML